
I am a doctoral researcher in the Nonlinear Systems and Control group at Aalto University, advised by Prof. Shankar Deka and funded by the Intelligent Work Machines (IWM) doctoral program. My research lies at the intersection of control theory and formal methods, and aims to make autonomous systems trustworthy in safety-critical settings by designing control policies that are not only effective but also come with formal guarantees of safety, stability, and robustness.
More concretely, my work focuses on formal verification and provable controller synthesis for nonlinear dynamical systems, in particular for systems operating in uncertain environments, with applications to safety-critical cyber-physical systems such as robots and autonomous vehicles.
Publications [Google Scholar]
* Equal contribution. † Corresponding author.
-
Data-driven Reachability Verification with Probabilistic Guarantees
under Koopman Spectral Uncertainty
[IFAC WC 2026]
The 23rd IFAC World Congress [pdf] [code] -
PyBDR: Design and Usage of a Toolkit for Set-Boundary Based
Reachability Analysis
[SCP 2026]
Science of Computer Programming, vol. 253, art. 103498 [doi] [code] About PyBDR
PyBDR is an open-source Python toolbox for reachability analysis of dynamical systems, built on the set-boundary method. Instead of propagating the whole initial set, it propagates only a thin set enclosing its boundary. This reduces the wrapping effect, so the reachable sets stay tight for large initial sets and long time horizons, and non-convex initial sets are handled directly.
- Systems: linear, nonlinear and neural ODEs.
- Set representations: intervals, zonotopes and polytopes.
- Usage: installs with pip on Linux, macOS and Windows without system libraries; example notebooks for every algorithm, including a Colab demo; interactive 3D plots.
pip install "pybdr @ git+https://github.com/ASAG-ISCAS/PyBDR"[GitHub] [latest release] [documentation] [Colab demo]
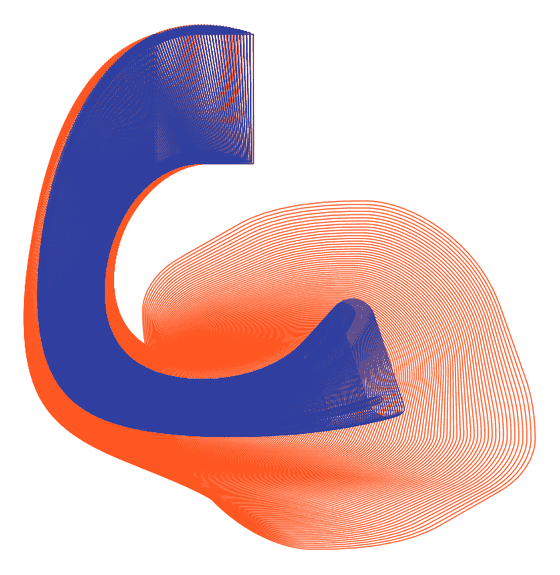
Lotka–Volterra model ẋ = 1.5x − xy, ẏ = −3y + xy initial set [2.5, 3.5]², time t ∈ [0, 2.2] whole initial set propagated boundary only (PyBDR) -
Provable Reach-avoid Controllers Synthesis for Deterministic
Discrete-time Systems Based on Convex Computations of Controlled
Reach-avoid Sets
[Book Chapter]
Design and Verification of Cyber-Physical Systems (Fränzle
Festschrift), LNCS vol. 16060, pp. 223–243, 2026
[doi] [pdf] -
Reach-Avoid Model Predictive Control with Guaranteed Recursive
Feasibility via Input Constrained Backstepping
Preprint , arXiv:2604.03407, 2026.[pdf] [code] -
Backstepping Reach-avoid Controller Synthesis for Multi-input
Multi-output Systems with Mixed Relative Degrees
[CDC 2025]
The 64th IEEE Conference on Decision and Control [pdf] [doi] [code] -
Time-to-reach Bounds for Verification of Dynamical Systems using the
Koopman Spectrum
Preprint , arXiv:2411.05554, 2024.[pdf] -
PyBDR: Set-boundary based Reachability Analysis Toolkit in Python
[FM 2024]
26th International Symposium on Formal Methods [pdf] [code] -
Inner-approximate Reachability Computation via Zonotopic Boundary
Analysis
[CAV 2024]
36th International Conference on Computer Aided Verification [pdf] -
Discernible Image Mosaic with Edge-aware Adaptive Tiles
[CVM 2019]
Computational Visual Media, vol. 5 [doi]
